Embodied Intelligence

Reinforcement Learning, Simulation & Future AI

Overview

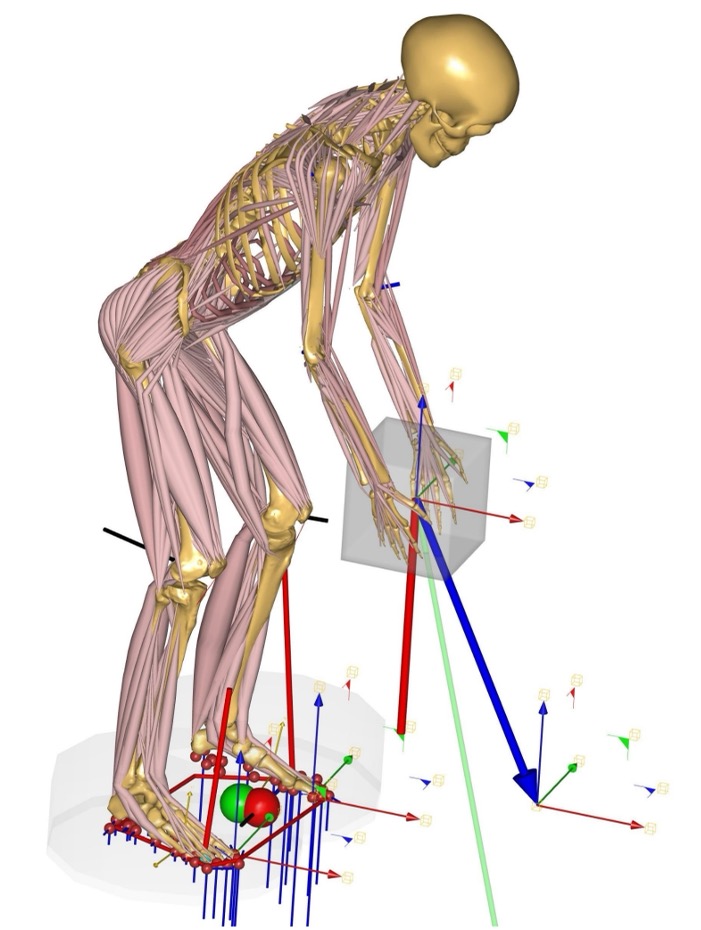
To create truly intelligent robots, we must bridge the gap between simulation and the real world. My research in Embodied Intelligence focuses on using Reinforcement Learning (RL) and physics-based simulations to train robust control policies.

I am currently working on Simulation-to-Real Integrated Control, combining simulation-generated data with real sensor inputs to estimate joint moments and develop adaptive assistance strategies for lower-limb exosuits.

Embodied Intelligence

Current Research

Simulation-Based Gait Moment Estimation and Exosuit Control

Ongoing Research

Expanding work to lower-limb exosuits. Combining simulation-generated and real sensor data to estimate joint moments and develop control strategies. Utilizing deep learning to minimize the sim-to-real gap and enable adaptive assistance.

Reinforcement Learning Sim-to-Real Exosuits