Soft Robotics

Origami Grippers & Deep Learning-based Force Estimation

Overview

Soft robotics offers a promising solution for handling delicate and irregular objects where traditional rigid robots fail. My research focuses on overcoming the limitations of soft grippers, such as the difficulty in estimating grip force due to material non-linearity.

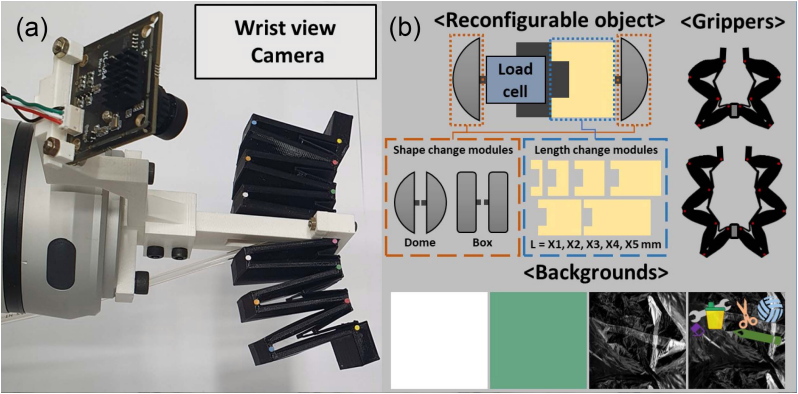
I have developed deep learning-based methods, such as OriGripNet, which estimate gripping force by combining visual data with physical parameters, eliminating the need for embedded sensors that can compromise the gripper's flexibility.

Soft Robotics

Key Publications

Impact of Physical Parameters and Vision Data on Deep Learning-Based Grip Force Estimation for Fluidic Origami Soft Grippers

Eojin Rho, Woongbae Kim, Jungwook Mun, Sung Yol Yu, Kyu Jin Cho, Sungho Jo

Knowing the gripping force being applied to an object is important for improving the quality of the grip. In this paper, we present a vision-based neural network (OriGripNet) that estimates gripping force by combining RGB image data with key parameters extracted from the physical features of a soft gripper. OriGripNet showed a mean average error (MAE) of 0.0636 N when tested for untrained objects.

Soft Gripper Deep Learning Force Estimation